4.Accelerometer and Gyroscope
Description
The back panel of the UNIHIKER is equipped with a 6-axis accelerometer-gyroscope sensor, which can read the X, Y, and Z values of acceleration individually, as well as the total strength in X, Y, and Z directions, and the X, Y, and Z values of the gyroscope.
Syntax
- Accelerometer: accelerometer.get_x() accelerometer.get_y() accelerometer.get_z() accelerometer.get_x()
- Gyroscope: gyroscope.get_x() gyroscope.get_y() gyroscope.get_z()
Parameters
**None
Return
Accelerometer values and gyroscope values
Example Description
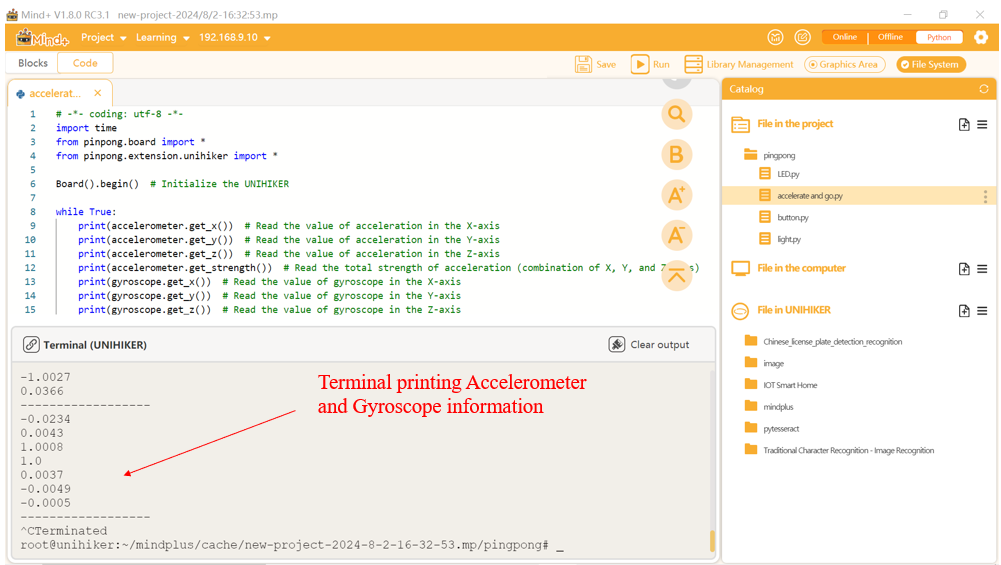
The code below can be used to sense changes in value through the Accelerometer and Gyroscope sensor on UNIHIKER.
Hardware Required
Example Code
# -*- coding: utf-8 -*-

import time
from pinpong.board import *
from pinpong.extension.unihiker import *

Board().begin()  # Initialize the UNIHIKER

while True:
    print(accelerometer.get_x())  # Read the value of acceleration in the X-axis
    print(accelerometer.get_y())  # Read the value of acceleration in the Y-axis
    print(accelerometer.get_z())  # Read the value of acceleration in the Z-axis
    print(accelerometer.get_strength())  # Read the total strength of acceleration (combination of X, Y, and Z axes)
    print(gyroscope.get_x())  # Read the value of gyroscope in the X-axis
    print(gyroscope.get_y())  # Read the value of gyroscope in the Y-axis
    print(gyroscope.get_z())  # Read the value of gyroscope in the Z-axis
    print("------------------")
    time.sleep(1)